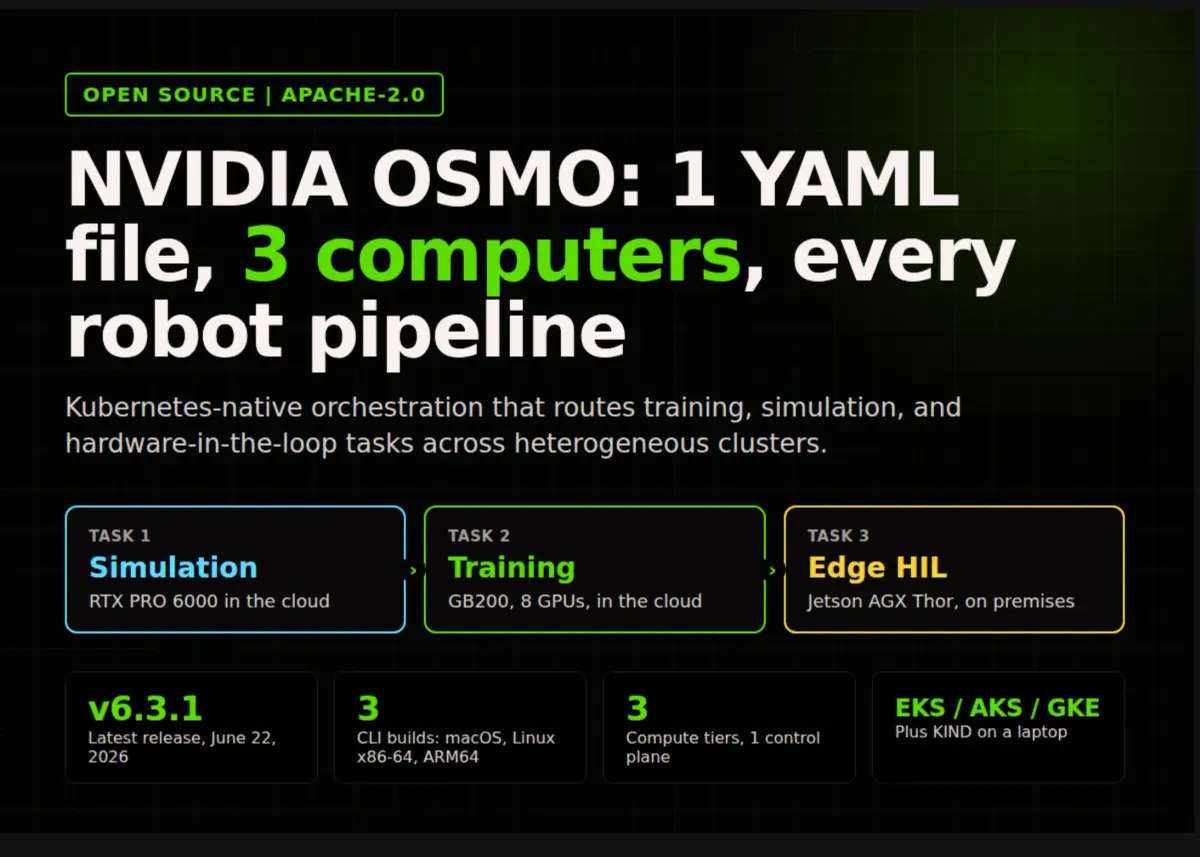
NVIDIA Open-Sources OSMO: One YAML Orchestrates Physical AI Training, Simulation, and Robot Testing
Robot developers do not have one compute problem. They have 3. A policy is trained on GB200 or H100 clusters, tested in Isaac Sim on RTX GPUs, then validated on a Jetson mounted inside a real robot. Each tier has its own cluster, its own scheduler, and its own glue scripts. NVIDIA OSMO is NVIDIA’s answer to that fragmentation: an open-source, Kubernetes-native workflow orchestrator that lets a team describe the whole pipeline in a single YAML file and run it across every tier without touc
OSMO is an open-source workflow orchestrator that allows robot developers to describe their entire pipeline in a single YAML configuration file and run it across multiple computing environments without rewriting infrastructure code. Robot development requires three separate computing tiers: data-center GPUs for training policies, workstation-class RTX hardware for simulation and physics rendering, and edge devices like Jetson for deployment and hardware testing, each traditionally requiring its own tools and custom scripts. OSMO treats these three tiers as backends of one control plane, routing tasks to appropriate hardware pools based on platform requirements rather than requiring developers to specify individual clusters. The tool includes features such as interactive remote development, Kubernetes-native scheduling, dataset management, security controls with RBAC and OAuth2, and integration with AI coding agents.
One short email a day with the stories that matter. Free. Unsubscribe with one click.
Want to go deeper than the news? Explore live, cohort-based AI courses taught by practitioners.
Browse AI courses on Maven
Anthropic releases new Mythos and Fable models amid RSI concerns
Anthropic says the new models "show improvements in areas like coding, reasoning, and vision," as well as in communicating more clearly with users.
Also reported by The Verge, SiliconANGLE and MarkTechPost
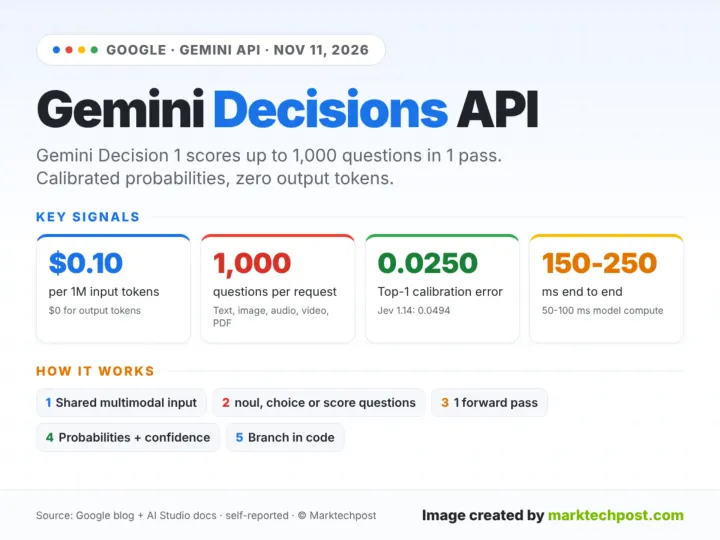
Google Launches Gemini Decisions API With Gemini Decision 1 at $0.10/M Tokens
Google has launched the Gemini Decisions API, powered by a new model, Gemini Decision 1 (gemini-decision-1). The Gemini Decisions API does not generate text. It scores up to 1,000 typed questions against one shared input and returns calibrated probabilities. For developers, this targets the small branching calls inside agents: routing, policy checks, tool selection and grading. Google prices it at $0.10 per 1M input tokens, with zero output tokens billed. TL;DR Size: Context is 262,144 t
Also reported by SiliconANGLE

Google releases Gemini 4 Carbon with agent ‘swarm’ feature
Google is rolling out its latest AI model, Gemini 4 Carbon, to the general public after releasing it to a select group of "cybersecurity defenders" two weeks ago. Google claims Carbon is its "strongest model" yet, and capable of competing with the very best systems from Anthropic and OpenAI. Google says Gemini 4 Carbon "pushes the frontier even further" than Argon, referring to the company's other frontier model that launched only last month. The company said Argon will likely
Gemini 4 Carbon is now available
The latest version aims to deliver improved performance while reducing the computational resources and energy required for AI operations.

Introducing AlphaProof Code: a breakthrough in verifying complex software at depth
AlphaProof Code agents wrote three million lines of proofs in Lean to verify Signal’s core encryption.
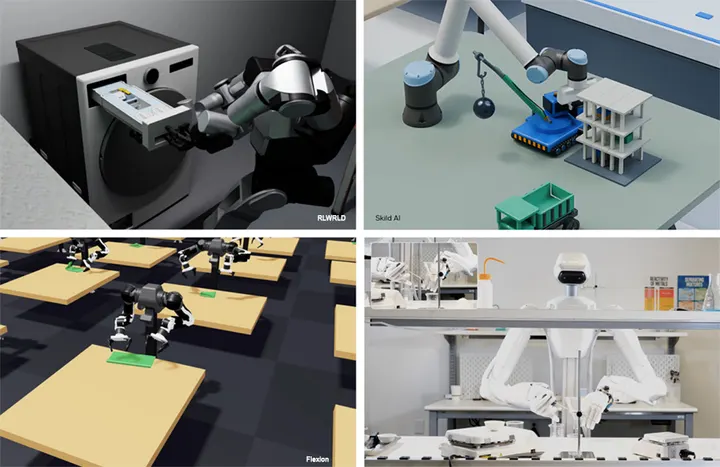
NVIDIA launches GR00T 2 and Isaac Lab 3.0 at CoRL
A range of developers, including RLWRLD, Skild AI, and Flexion, are already using NVIDIA’s latest technology. | Source: NVIDIA NVIDIA Corp. today introduced GR00T 2, its updated open frontier world action model, and Isaac Lab 3.0, the latest version of its open-source robot learning framework. The company made these announcements at the Conference on Robot Learning, or CoRL, in Austin, Texas. NVIDIA also gave a look at how its partners, like Ambi Robotics, Bosch Research, Dexmate, Dyna Rob